 RESEARCH PORTFOLIO
VAE-based Drone Action Generation for Policy Reuse in Reinforcement Learning
항공우주시스템공학회 2025 춘계학술대회
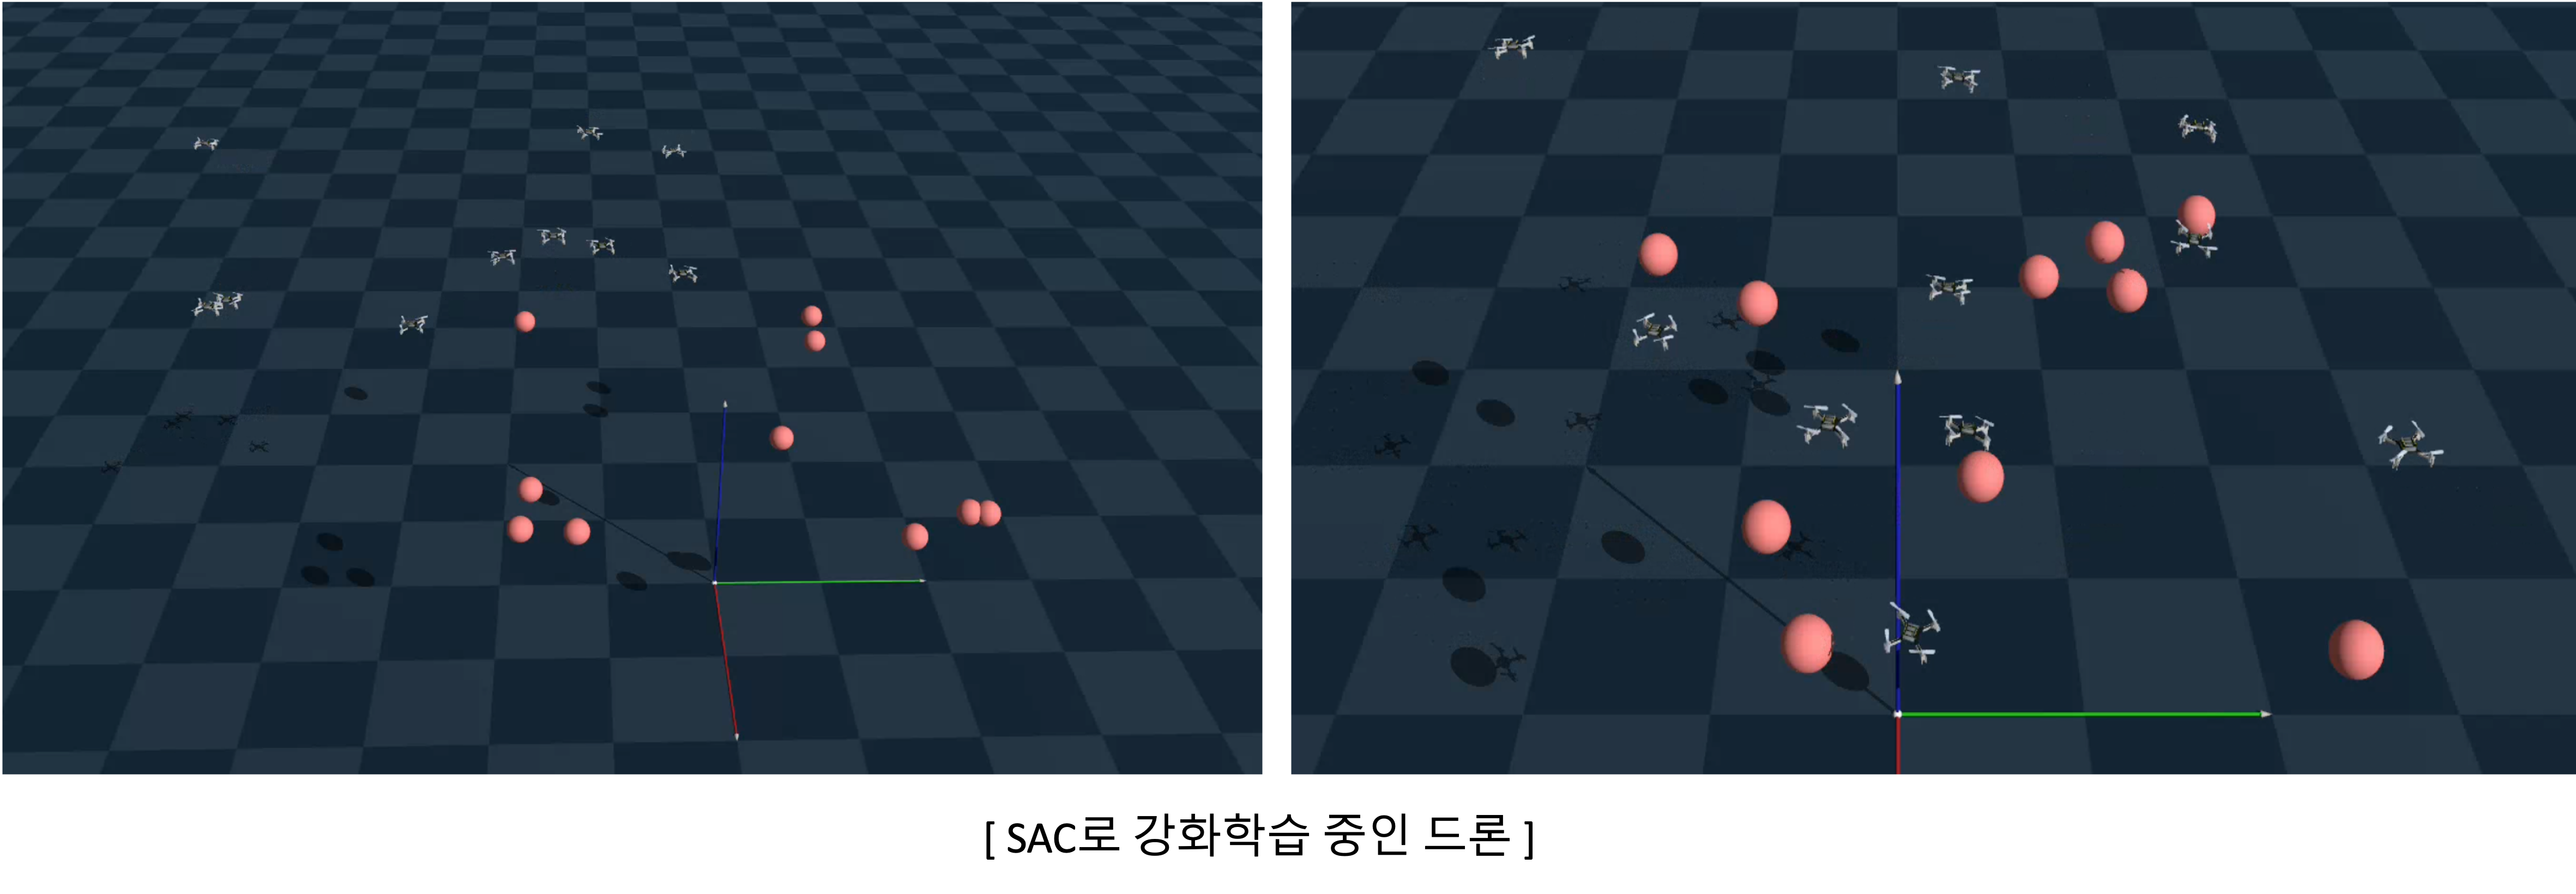
- Design of a VAE-based drone action generation model and execution of policy reuse and heterogeneous drone control experiments using SAC reinforcement learning
-
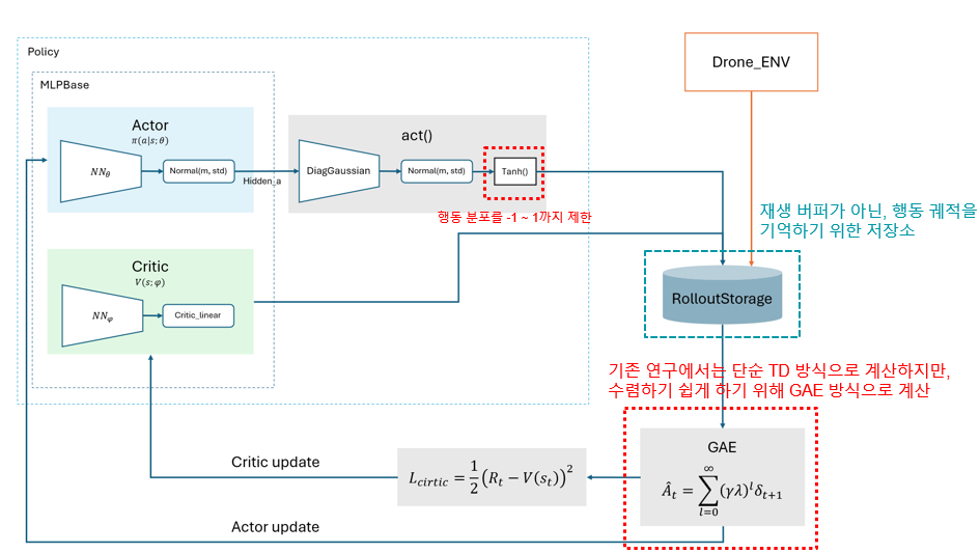
Conducted in-depth research on the reuse and transfer of reinforcement learning policies utilizing Soft Actor-Critic (SAC).
-
Configured virtual development environments using Docker on Ubuntu and custom-designed physics-based simulations utilizing the Genesis simulator.
-
Aimed to learn a shared policy applicable across heterogeneous drones by simultaneously training different drone models.
-
Designed an objective function based on the clear definition of ON and OFF policies.
-
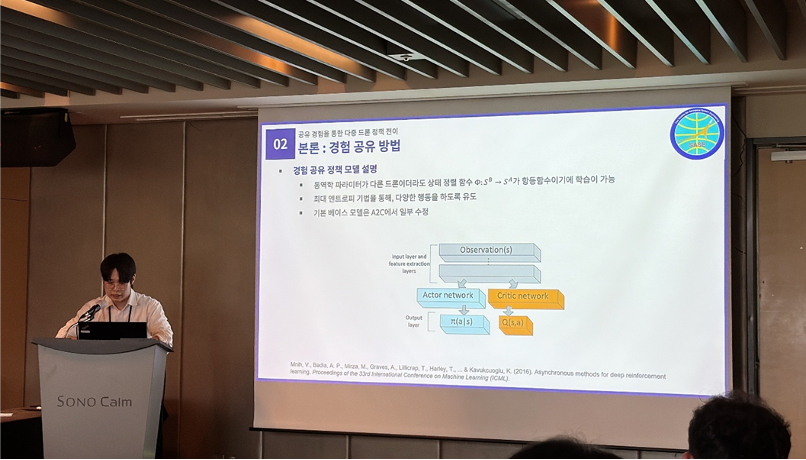
Presented the research findings at the 2025 Spring Conference of the Society of Aerospace System Engineering (SASE).