RESEARCH ARCHIVE

Projects.

How ideas were built and validated

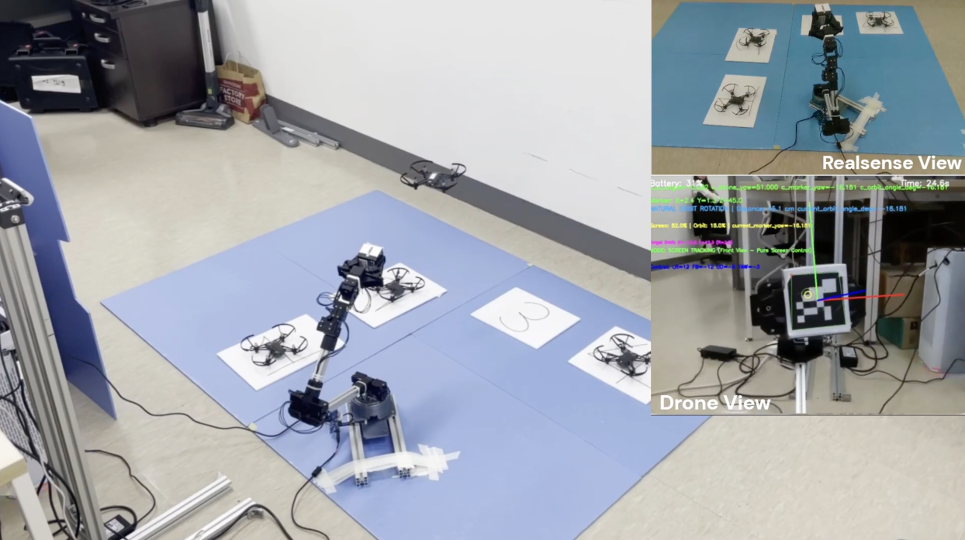
Drone Aerial Guidance System Utilizing a Robotic Arm

Developed an integrated system utilizing an ArUco marker on a ground robotic arm to guide drone flight and landing, controlled via a LangChain-based agent.

  • Key Implementation: PPO-based drone tracking, ACT-based robotic arm guidance, and LangChain agent integration.
  • Achievement: Korean Air Capstone Design Award

Drone, manipulator, VLA, Langchain

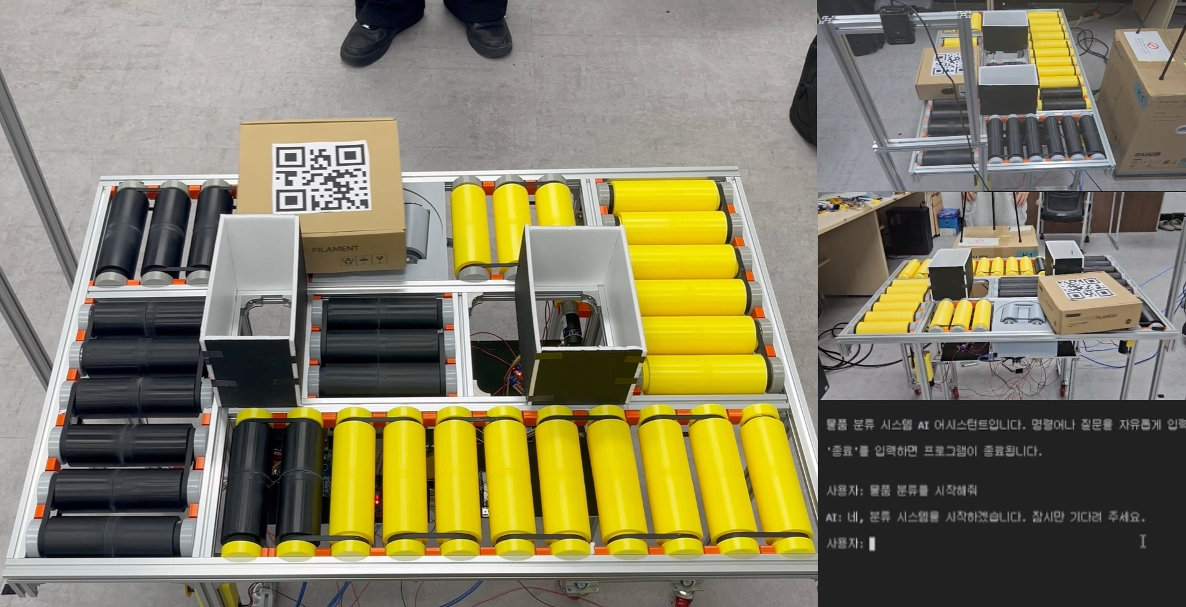
LLM Agent-Based Item Classification System

Developed a natural language-controlled item classification system by integrating an LLM agent with a custom-built Arduino-based wheel sorter.

LLM, Agent, LangChain, Arduino, Hardware Design

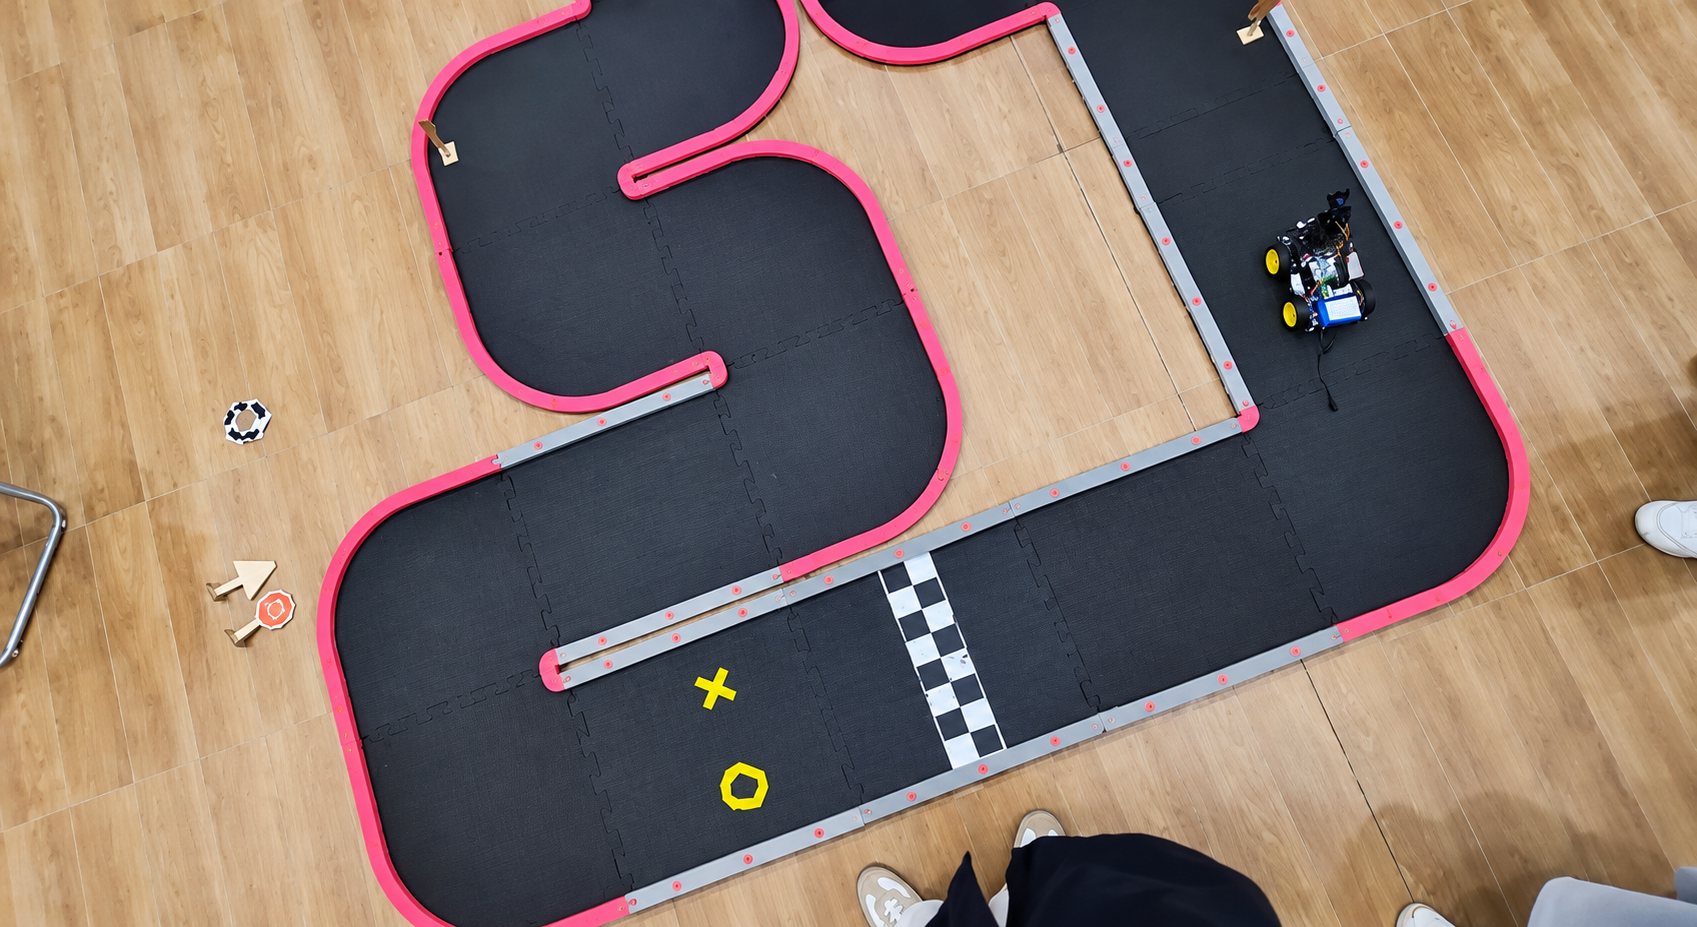
Optimization of Raspberry Pi-Based Autonomous Driving System

  • Developed a Raspberry Pi 4-based autonomous driving system, reducing track completion time by 58% through optimized image processing and YOLO-based perception.
  • Achievement: Excellence Award at the Gachon University Autonomous Driving Competition

YOLO, Image Processing, Multi-thread, FSM, Raspberry Pi

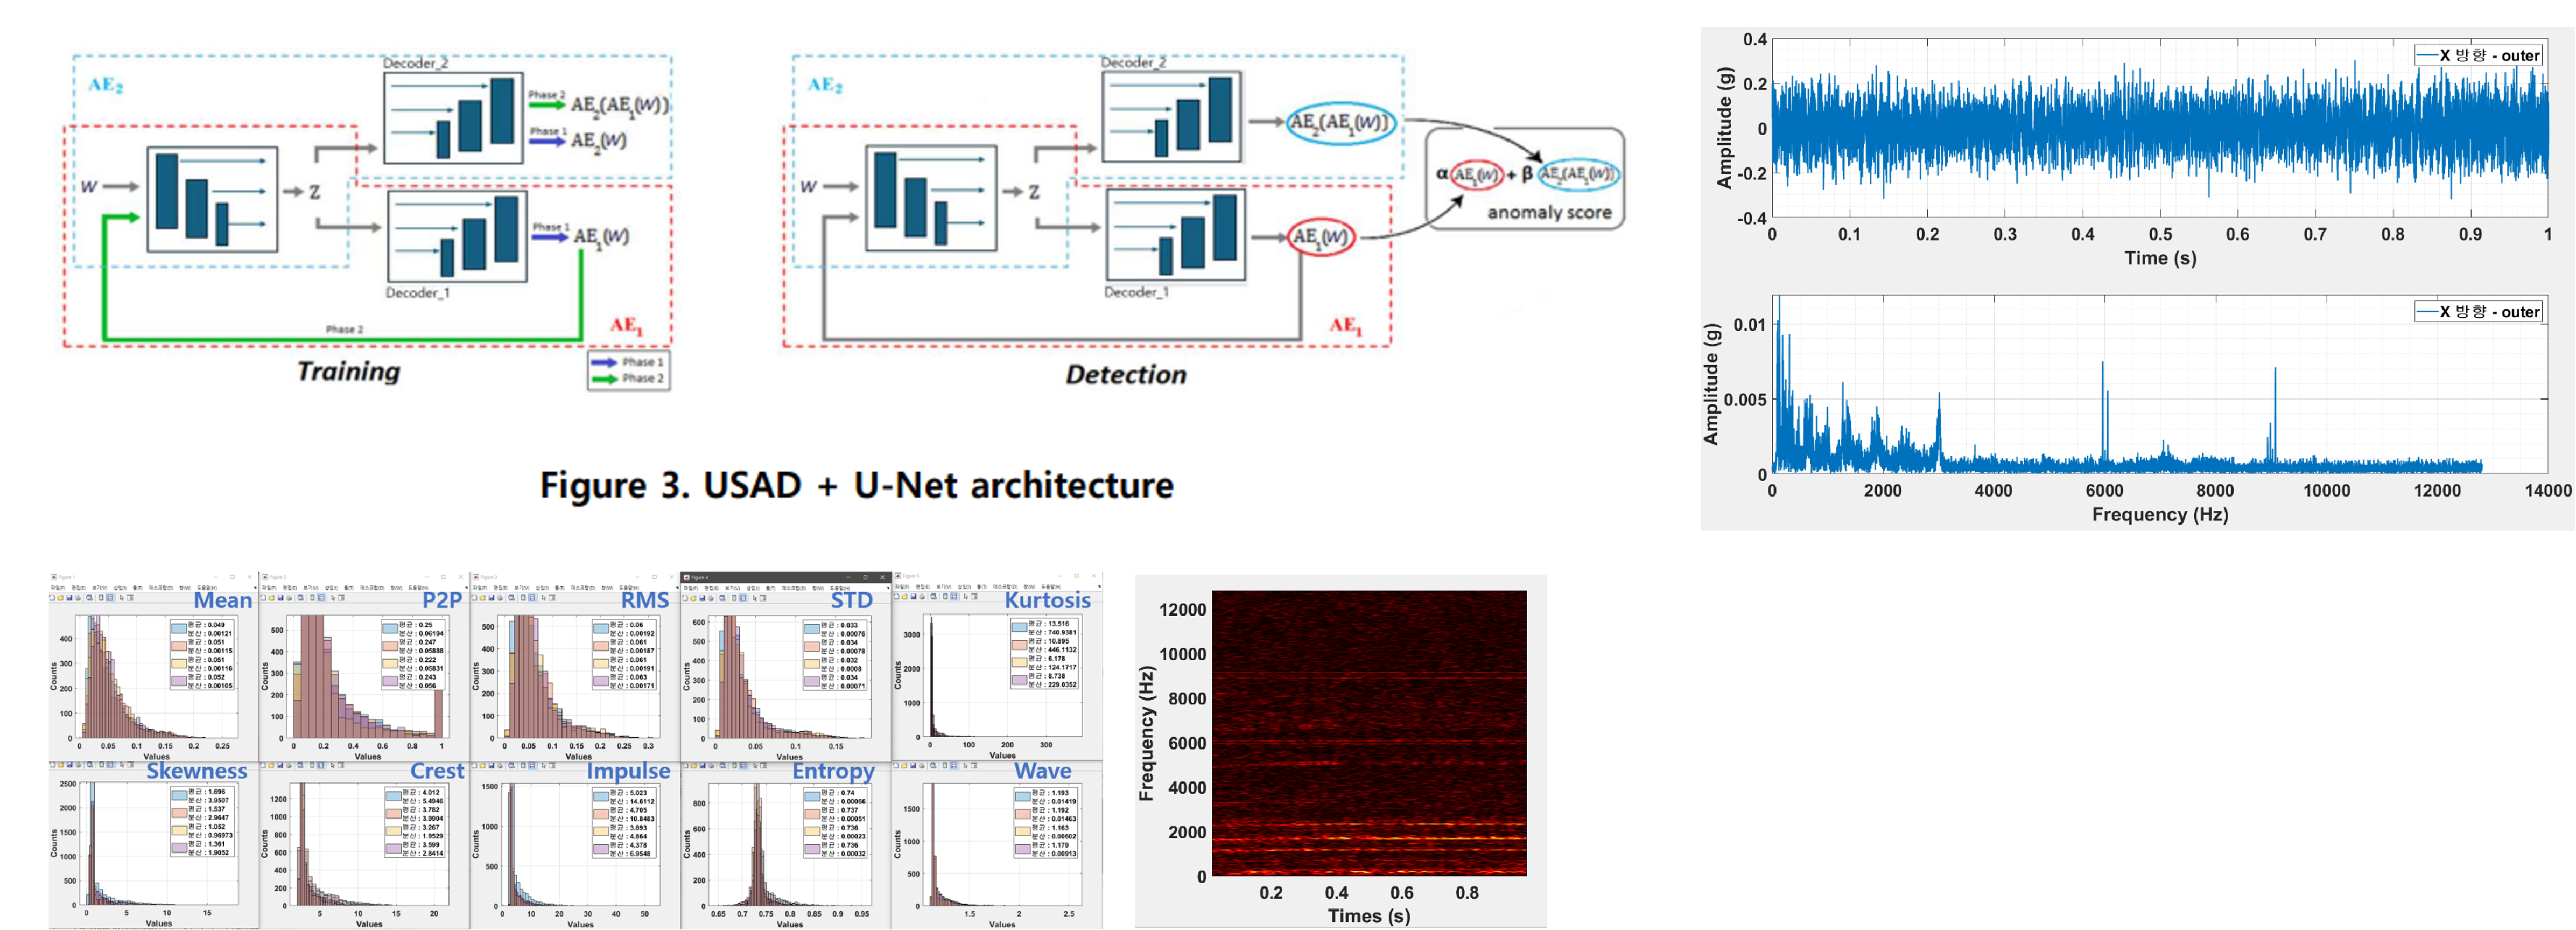
Vibration Signal-Based Bearing Anomaly Detection

Developed an anomaly detection model for bearing vibration data, improving accuracy by 29.67%p through signal analysis and autoencoder architecture modifications.

Signal Processing, FFT, Autoencoder, USAD, Anomaly Detection