 RESEARCH PORTFOLIO
Auto-Calibration Method for Multi-Conductor Differential Protection Relay (MCDPR) Operated by Dual LSTM Networks
대한기계학회 동역학·제어·로봇부문 2024년도 춘계학술대회
- Design and Experimental Validation of a Dual LSTM-Based MCDPR Automatic Shape Correction Model
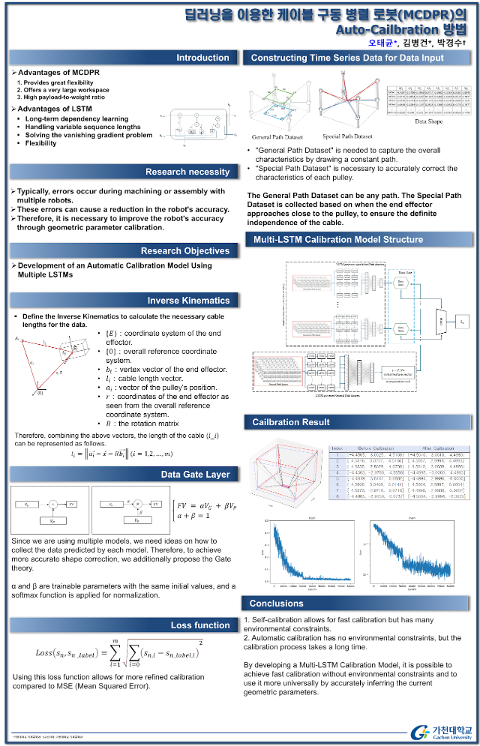
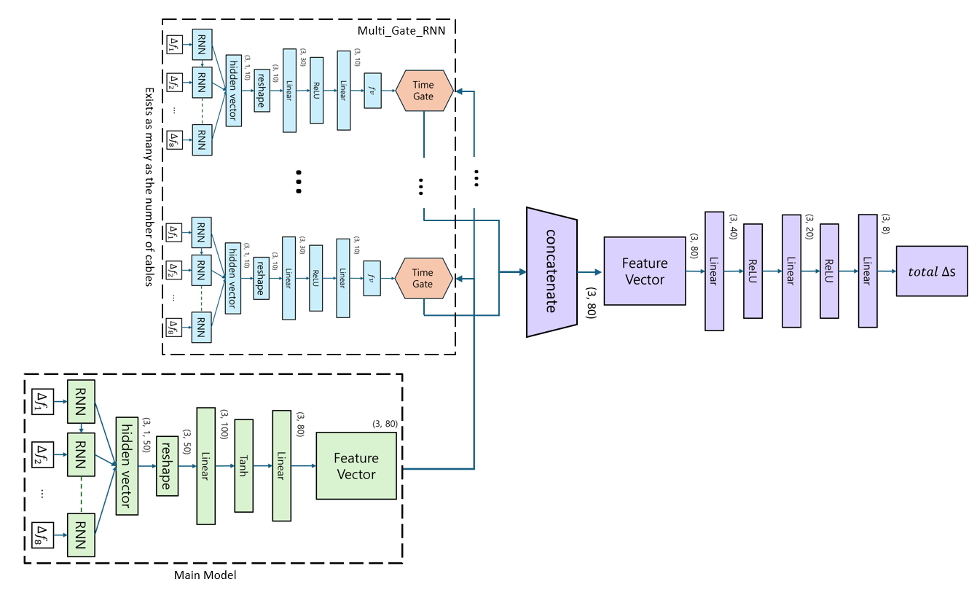
- Researched auto-calibration methods for Cable Driven Parallel Robots (CDPR).
- Developed an end-effector trajectory-based auto-calibration system and implemented a real-time calibration algorithm utilizing a Dual LSTM network, reducing the calibration processing time by 90%.
- Built a simulation using Unreal Engine to verify the accuracy of the model's inference results and cable tension calculations.
- Designed box actors to apply specific forces at designated positions on the end-effector at every tick, effectively reflecting real-world experimental data and achieving high state prediction accuracy.